Robotic Systems
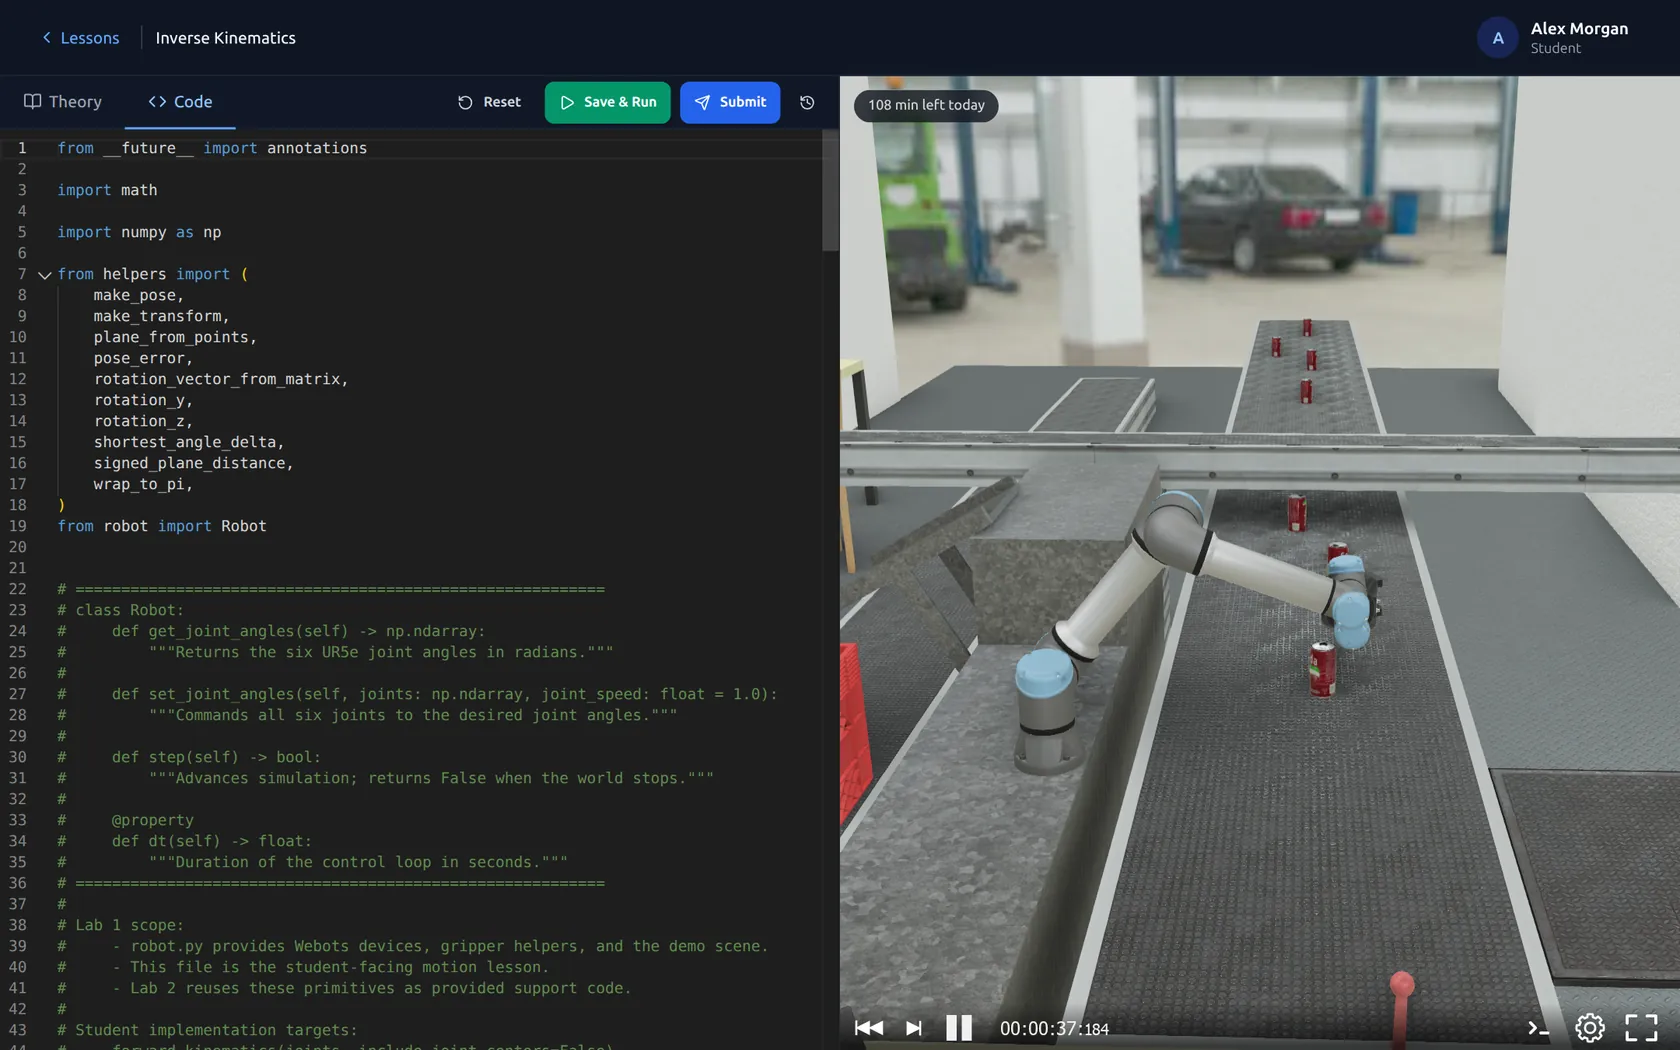
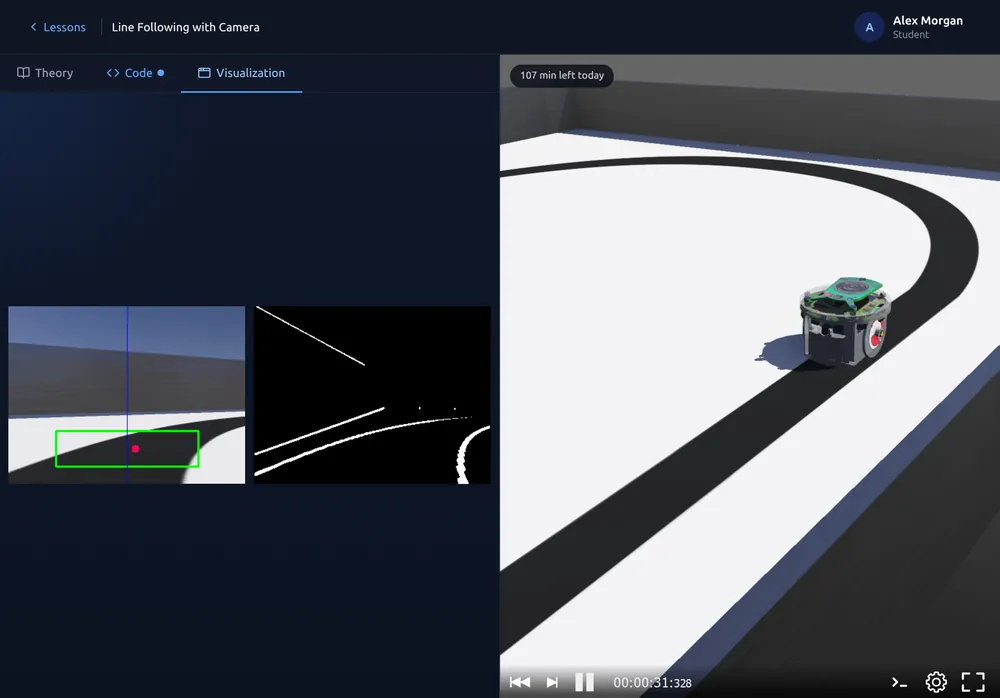
We develop navigation, localization, and motion planning, then connect the software to robot sensors and actuators. Our row-following project uses ROS 2, Isaac Sim, and Nav2.
See the Row-Following Project- Navigation, localization, and motion planning
- Behavior design and control
- Robot and sensor integration